Offline Reinforcement Learning
Sequential Decision Making
Generative Models
Role-Adaptive Policy Optimization for Offline Reinforcement Learning
Seonvin Cho, Soohyun Choi, Songnam Hong†
Preprint · †Corresponding author
-
Proposed Role-Adaptive Policy Optimization (RAPO), which learns policy-update
coefficients according to whether actions are used for critic bootstrapping or
for execution
-
Separated bootstrap and execution actors in TD3+BC and adapted only the inverse
temperature for IQL, improving both base algorithms on D4RL locomotion and AntMaze
Is One Step Enough for Offline Policy Improvement?
Soohyun Choi*, Seonvin Cho*, Songnam Hong†
Preprint · *Equal contribution · †Corresponding author
-
Studied multi-step proximal policy improvement that re-centers each stage on the
preceding policy, asking when a single improvement step is enough
-
Distinguished subdivision of a fixed total horizon from additional refinement,
with experiments on TD3+BC and IQL-based policy extraction in D4RL locomotion
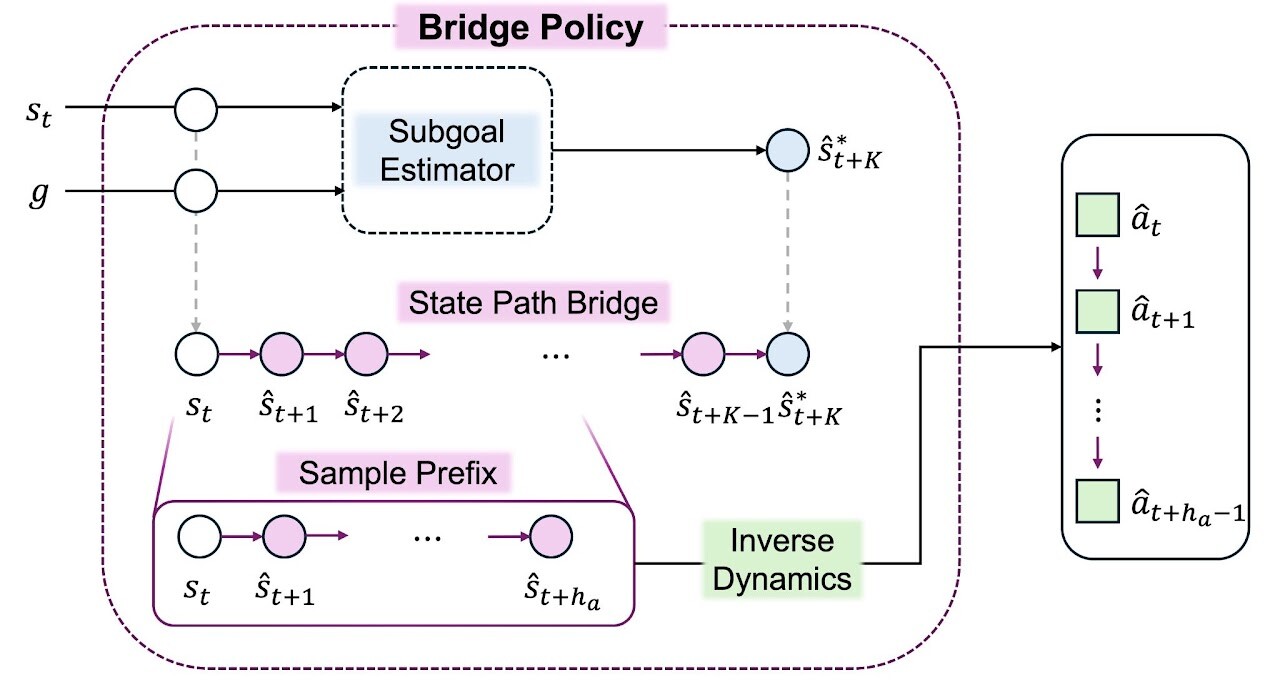
PathBridger: Subgoal Bridges for Offline Goal-Conditioned Reinforcement Learning
Soohyun Choi*, Seonvin Cho*, Songnam Hong†
Preprint · *Equal contribution · †Corresponding author
-
Developed a hierarchical offline GCRL framework that connects subgoal selection
to short-horizon execution through state-space bridges
-
Combined generative endpoint proposals, transitive value-based selection, and
inverse-dynamics decoding to produce executable action chunks from offline
trajectories
Ongoing Research
Extensions of PathBridger
-
Skill Learning and Composition:
Investigating how to learn reusable skills from offline trajectories and compose them for long-horizon goal-conditioned tasks.
-
Latent-Space Bridge Planning:
Exploring learned representations and geometrically structured latent spaces for goal-conditioned bridge generation and short-horizon execution.
Research Topics
Policy Optimization in Offline Reinforcement Learning
-
Treat behavior-regularized policy updates as proximal steps along a
critic-induced gradient flow
-
Use this view to reason about multi-step refinement under different policy
geometries and imperfect critic estimates
Generative Models for Sequential Decision Making
-
Study generative approaches to sequential decision making, including sequence
models, diffusion models, energy-based methods, and flow-based models
-
Use them for trajectory generation, planning, and long-horizon control